Robot learning · Human-in-the-loop learning · Reliable embodied AI

Metin Alp Dogan

I'm a first-year Ph.D. student in Computer Science at UCLA, where I'm fortunate to be advised by Prof. Yuchen Cui in the Robot Intelligence Lab. My research interests lie at the intersection of robot learning, human-in-the-loop learning, and safe and reliable embodied AI. I'm particularly interested in developing robot policies that can learn from human feedback, be interpretable and steerable, and operate reliably under real-world uncertainty.

I was selected as a Fulbright Scholar by the Fulbright Commission and subsequently completed my M.S. in Electrical and Computer Engineering at UCLA. Before joining UCLA, I was a research intern at the Max Planck Institute for Intelligent Systems, where I worked with Prof. Metin Sitti on untethered magnetic milli-robots for biomedical applications. My research experiences have spanned both the physical design and control of robotic systems and the development of learning-based approaches to robot intelligence, shaping my interest in building robots that are not only capable, but also reliable and trustworthy.
x0 · t = 0click to resample

Education

  • Ph.D. in Computer Science, University of California, Los AngelesDepartmental Fellowship 2026 – present
  • M.S. in Electrical & Computer Engineering, University of California, Los AngelesGPA 4.0/4.0 · Fulbright Scholar 2024 – 2026
  • B.S. in Electrical & Electronics Engineering, Boğaziçi UniversityTop 10% of class 2020 – 2024

News

  • Nov 2026Visible Touch and Meta-Ctrl are both Spotlights at CoRL 2026.
  • Sep 2026Started my Ph.D. in Computer Science at UCLA with a Departmental Fellowship.
  • Jun 2026Finished my M.S. in ECE at UCLA.
  • Sep 2024Moved to Los Angeles as a Fulbright Scholar and joined the Robot Intelligence Lab.
  • Jun 2023Our pangolin-inspired magnetic robot is out in Nature Communications.

Publications

newest first · * equal contribution

Visible Touch: Rendering Contact for Visuomotor Policies

Metin Alp Dogan*, Edward Sun*, Feng Xu*, Daniel Wu, Allen Peng, Dennis Hong, Yuchen Cui

SpotlightConference on Robot Learning (CoRL) 2026

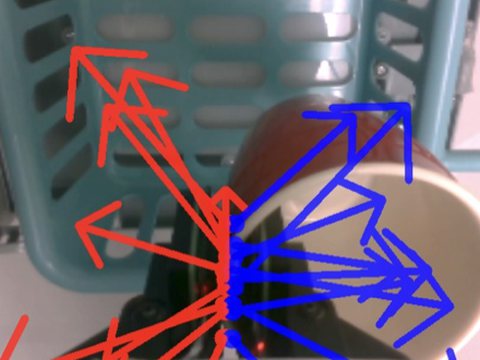
Draw contact as arrows on the camera image and any image-conditioned policy, pretrained VLAs included, can use touch with no architecture change: +15.7 pp on LIBERO, +30 pp for π0.5 on real contact-rich tasks, with a sub-$50 open-source sensor.

projectarXivhardware

Meta-Ctrl: Guaranteed Plan Generation by Decoupling Syntactic and Semantic Constraints

Gwen Yidou-Weng, Edward Sun, Tianyi Ma, Metin Alp Dogan, Benjie Wang, Allen Peng, Guy Van den Broeck, Yuchen Cui

SpotlightConference on Robot Learning (CoRL) 2026

Constrained decoding over meta-tokens guarantees that LLM robot plans satisfy syntax, preconditions, goals and ordering while keeping the LM's plan quality; a small open model reaches the best reported subgoal success on WAH-NL.

projectarXiv

Pangolin-Inspired Untethered Magnetic Robot for On-Demand Biomedical Heating Applications

Ren Hao Soon*, Zhen Yin*, Metin Alp Dogan, Nihal Olcay Dogan, Mehmet Efe Tiryaki, Alp Can Karacakol, Asli Aydin, Pouria Esmaeili-Dokht, Metin Sitti

JournalNature Communications 14, 3320 · 2023

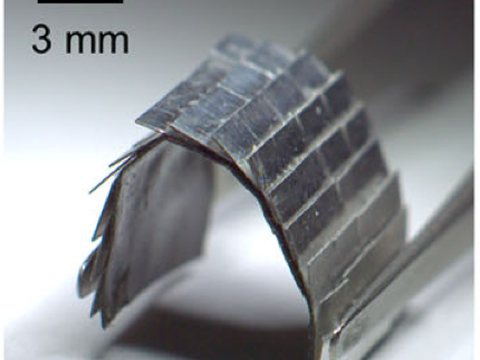
A soft magnetic robot with overlapping metal scales, like a pangolin's: it shape-morphs under low-frequency fields and heats above 70 °C from more than 5 cm away under high-frequency fields.

paper

Projects

Conformer Decoder for Intracortical Speech BCIs

Adapted the ASR Conformer to decode phonemes from 256-channel intracortical recordings (Brain-to-Text ’24), adding day-specific input layers, SpecAugment and intermediate CTC. Phoneme error rate 0.161 vs. 0.217 for the GRU baseline, with no language model.

EVEREST: Decoding Keystrokes from Wrist sEMG

TDS convolutions for short muscle-activation patterns feeding a three-layer LSTM, plus amplitude scaling and tuned SpecAugment, on Meta’s emg2qwerty. Test character error rate 13.29 vs. 21.91 for the baseline.

Artificial Potential Function Navigation for a TurtleBot

Robot-centric navigation function U = γk/β: an attractive goal term over a product of obstacle barrier terms, with Kinect RGB-D colour segmentation locating the target and obstacles. Its normalized gradient steers the TurtleBot in ROS and Gazebo. The thumbnail runs the same field live.

Experience

2024 – now

Robot Intelligence Lab, UCLA Los Angeles

Graduate Student Researcher · with Prof. Yuchen Cui

Asynchronous inference for diffusion and VLA policies (π0, π0.5): execution-reference anchoring lifts simulated manipulation success from 26.5% to 58.5% under 600 ms latency. Execution-supervised critics for robot program generation (AUROC 0.76 → 0.91). DARPA-funded work with Prof. Guy Van den Broeck on HMMs and Bayesian inference.

2023 – 2024

Automatic Control & Microprocessors Lab, Boğaziçi Istanbul

Undergraduate Researcher · with Profs. Kemal Cılız and Mehmet Akar

Built a rotary inverted pendulum and compared LQR, full-state feedback and PID on hardware and in Simulink.

2022

Max Planck Institute for Intelligent Systems Stuttgart

Research Intern, Physical Intelligence Dept. · with Prof. Metin Sitti

Modeled the nonlinear dynamics of magnetically actuated robots to close the sim-to-real gap (→ Nature Communications); 3D tumor segmentation in brain MRI.

Teaching

  • Graduate Reader, C247A/B Neural Networks & Deep Learning, UCLA
  • Teaching Assistant, EE 450 Control Technology & Design, Boğaziçi

Service

  • Fulbright Ambassador, UCLA, 2025
  • Graduate Representative, Turkish Student Association at UCLA
  • President, IEEE Student Branch at Boğaziçi, 2021 – 2023